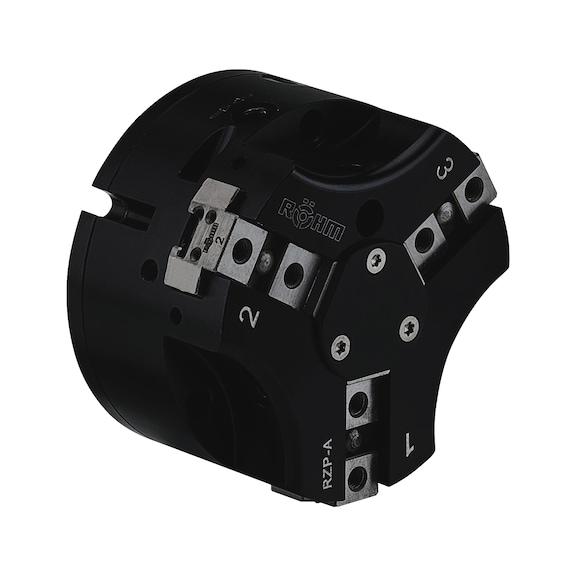


RÖHM RZP-A 160/3-1, centric gripper, long jaw stroke
Brand: RÖHM
Description Short: RZP-A 160/3-1, centric gripper, long jaw stroke
Art.-no. 95308512
Manufacturer article no. 435045
EAN 4019208336145
Brief description: Available in sizes 64 to 160, each with two stroke variants. Optionally available with clamping force safety device and/or dust cover. Gripper fingers are secured using centring sleeves (included in the scope of delivery). Technical features: Centric clamping in a compact design made from high-strength, hard-coated aluminium alloy; all functional parts made from hardened steel for maximum service life; wedge hook principle with pneumatic actuation; position detection possible via inductive and magnetic sensors; optionally available with FKM seals for higher temperatures up to 150 °C (on request); Integrated purge air connection to prevent contamination Applications: Universal gripping of round and cylindrical workpieces using three centric gripper fingers for handling with robots or gantries. Advantages: High gripping force combined with low weight and a compact design; maximum flexibility thanks to versatile connection and mounting options; long service life and high reliability thanks to specially ground base jaws in a proven T-slot guide Further information: RZP-A 160/3-1, 3-jaw pneumatic centric gripper, large jaw stroke, standard gripping force

Brand | RÖHM |
EAN | 4019208336145 |
Manufacturer Part Number | 435045 |
Minimum order quantity | 1 |
Description Short | RZP-A 160/3-1, centric gripper, long jaw stroke |
Gross Weight | 4.350 kg |
Last viewed

KS TOOLS Tile chisel, 4-sided, 6x200 mm

BOSCH EXPERT C470 Sandpaper multi-hole 125 mm K 240 50-piece 2608901132

METABO Diamond countersink 68 mm x M 16 Universal 628095000

ELTEN safety lace-up boots RENZO GTX XXW Mid ESD S3 CI 765491-36 Size 36

WERA Combination screwdriver with 6 bits Kraftform Compact 28 SB 05073240001

KS TOOLS Bayonet inlet adapter, D: 56 mm

KS TOOLS Bayonet inlet adapter, D: 38 mm

KS TOOLS TX angle pin wrench, short, T25

ATORN Twist drill VA HSSE, DIN 340, 1.1 mm x 60 mm x 37 mm, 130°

KS TOOLS Clamping nut spare part no. 29